probot-sdk Live
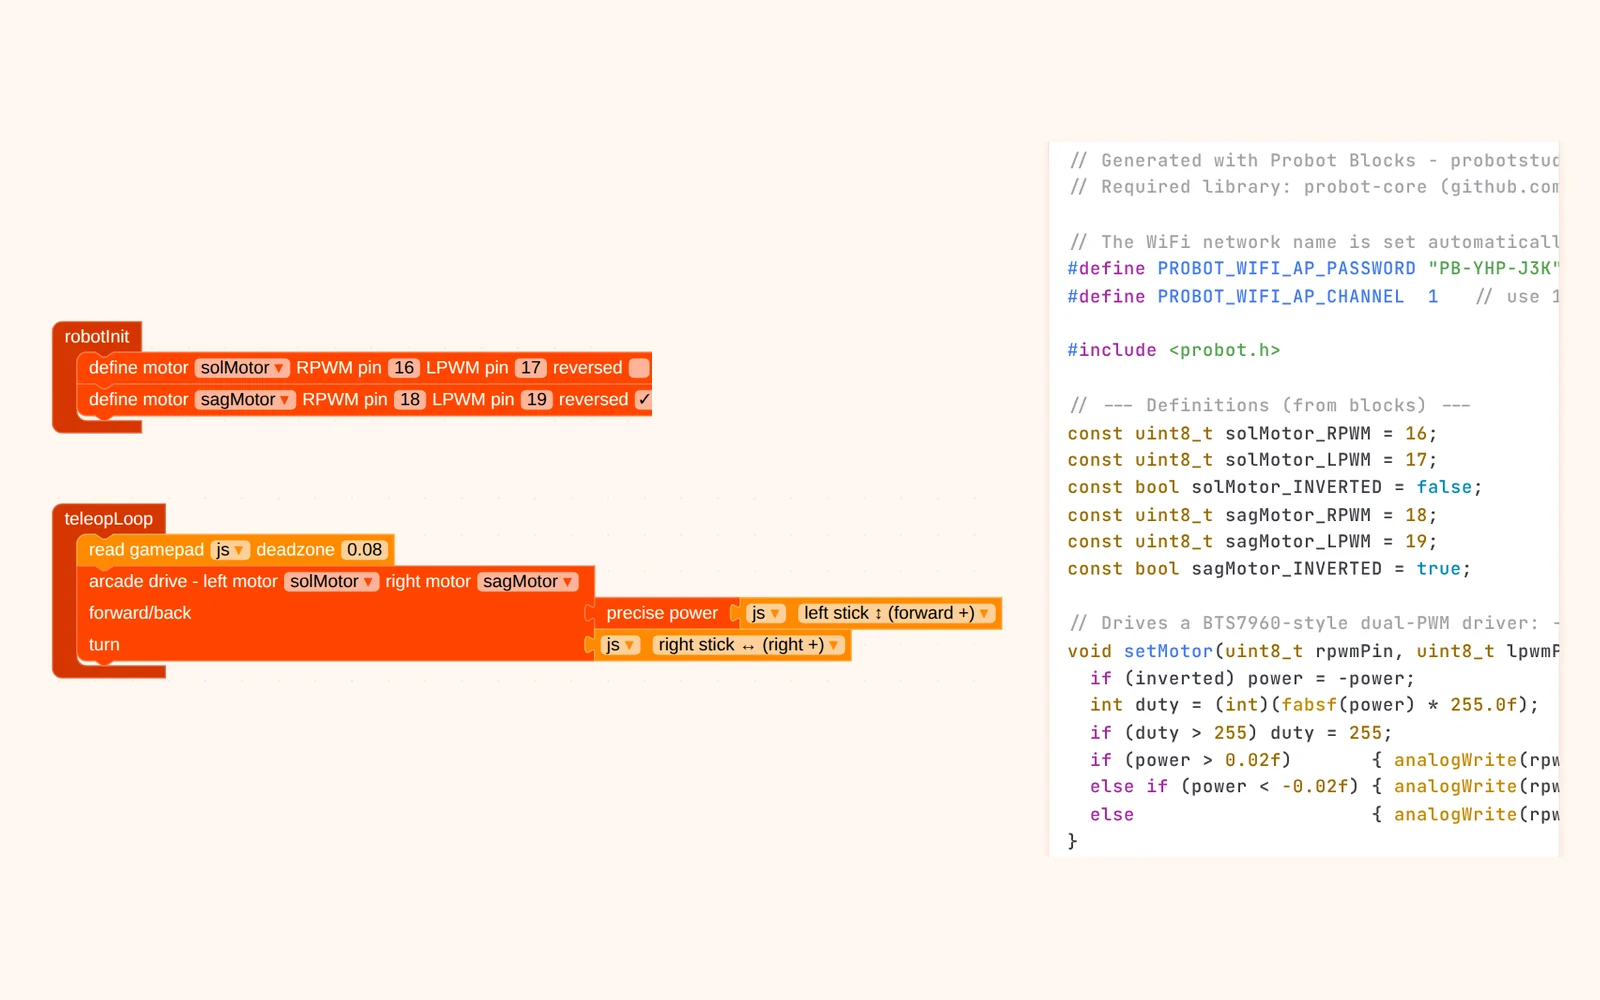
A header-only C++ control stack for ESP32 robots: PID, LQR, Kalman filtering, odometry and a command scheduler.
- Role
- Author (stable branch)
- Period
- 2025–2026
- Team
- Probot Studio
- Stack
- C++17 · ESP32 · FreeRTOS
What I did
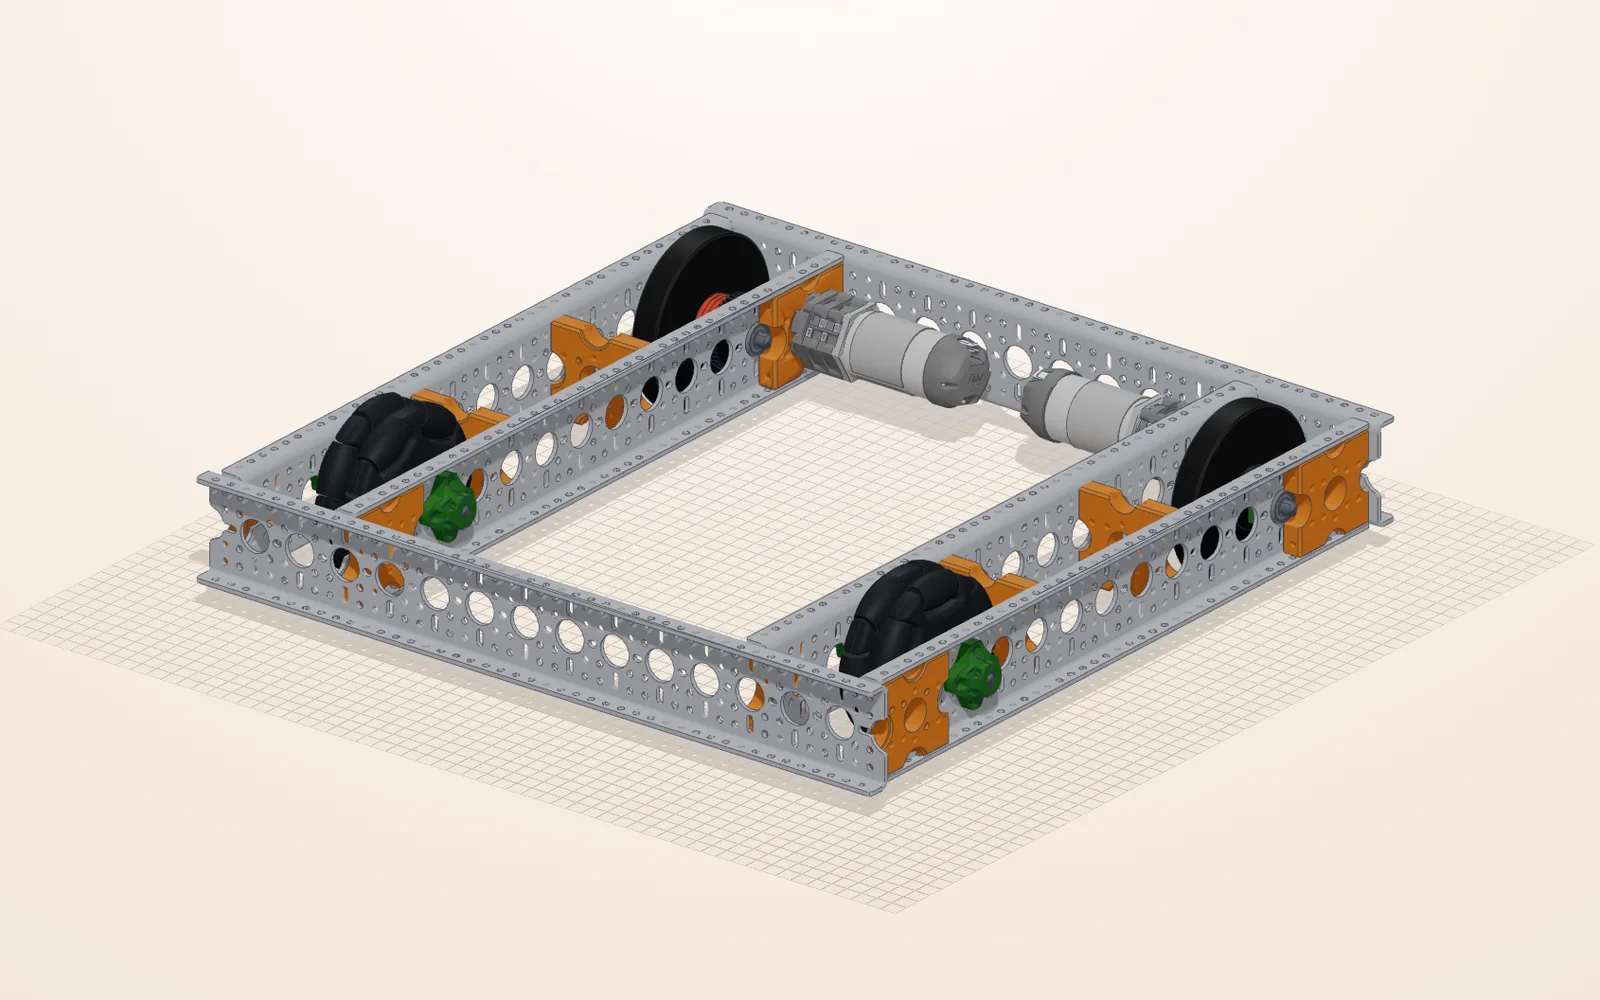
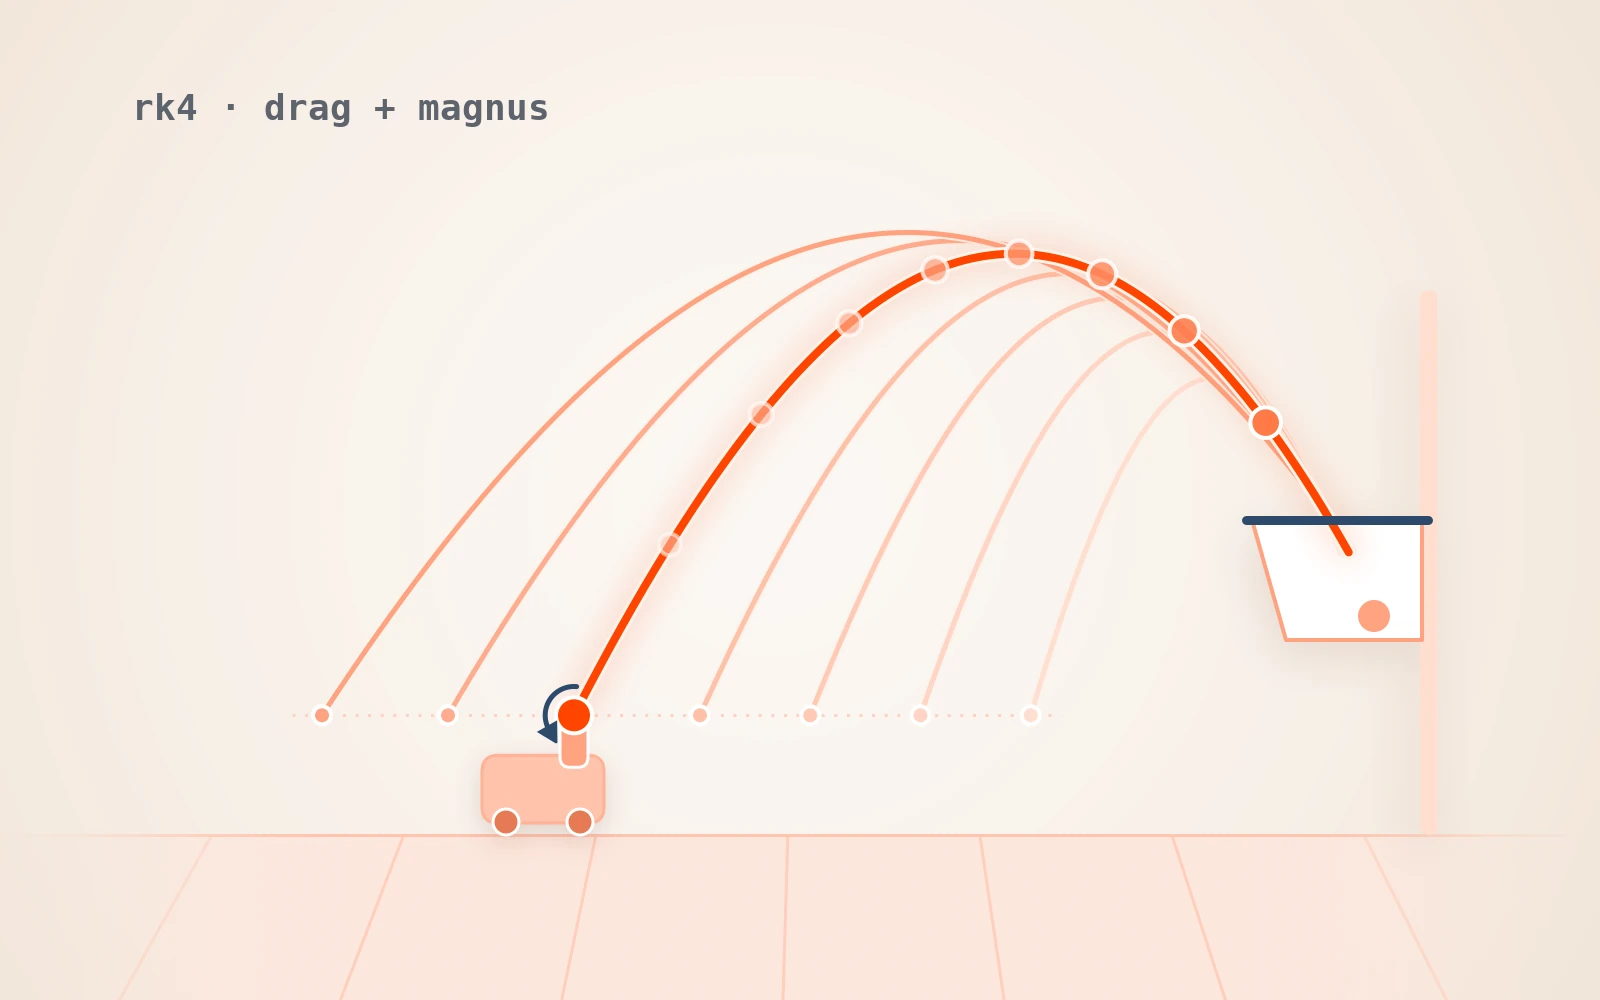
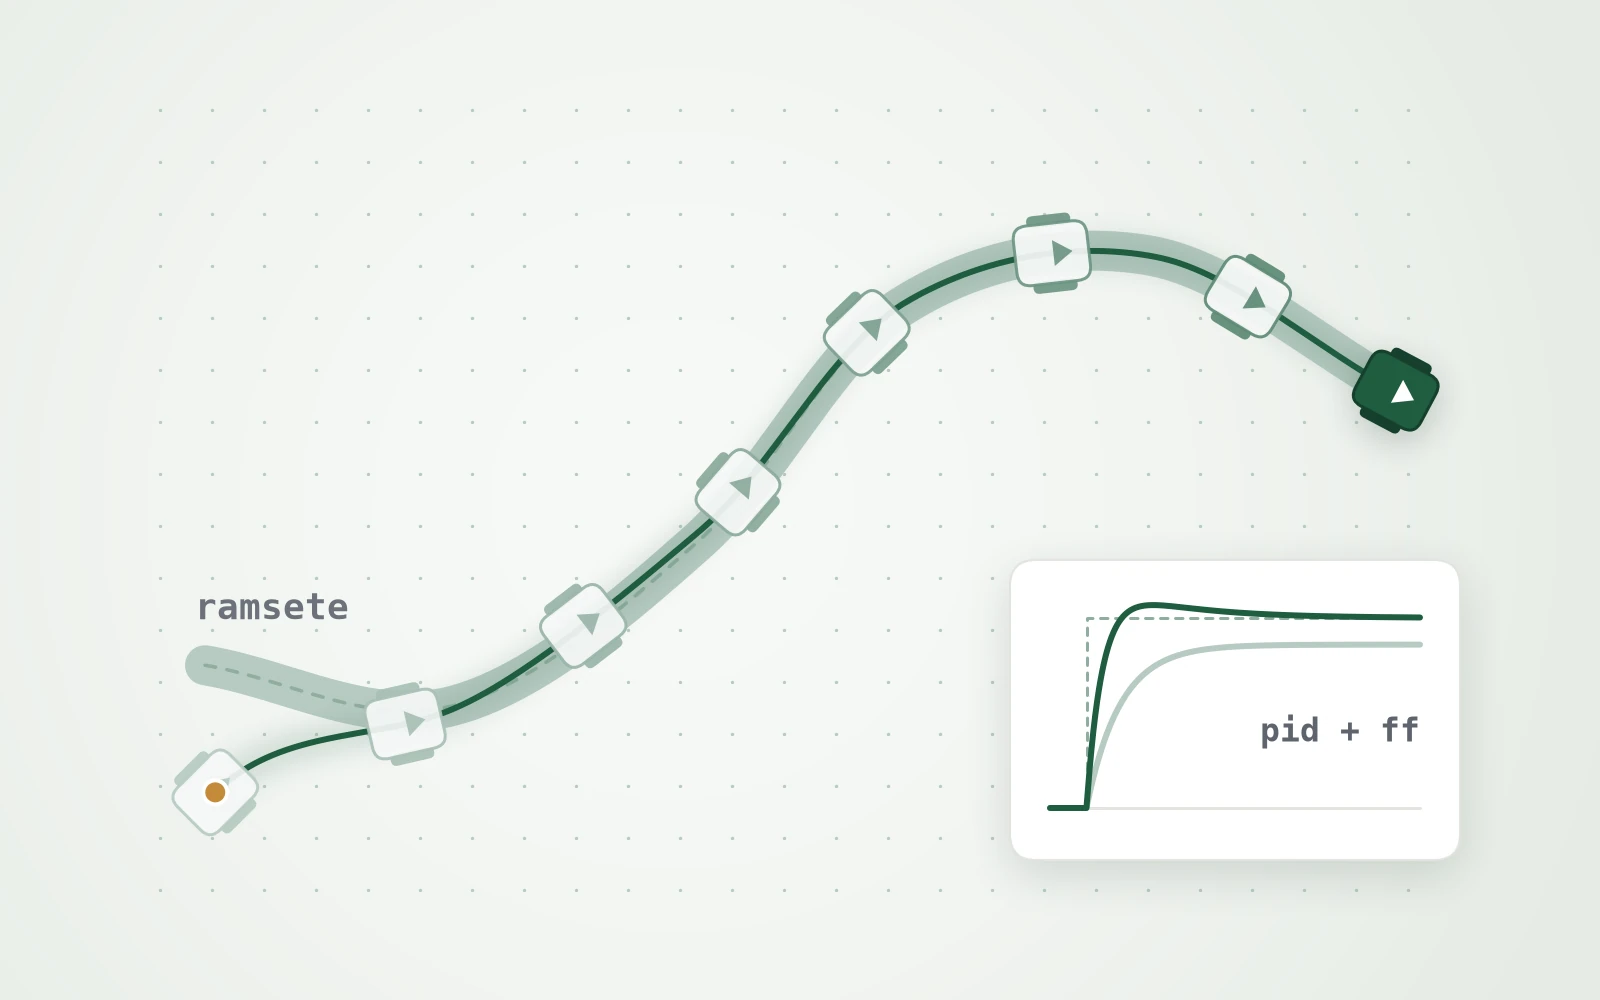
I implemented a header-only C++ control stack for ESP32 robots: PID and feedforward, LQR, a Kalman filter, mecanum odometry, RAMSETE path following and a WPILib-style command scheduler. It brings FRC-style control (WPILib-style commands, LQR, RAMSETE) to a small ESP32 board.