Floor-cleaning robot (ROS 2) Archive
A coverage path planner for a ROS 2 floor-cleaning robot: from a SLAM map to parallel sweep passes.
- Role
- Coverage planner and robot software setup
- Period
- 2023–2024
- Team
- Product prototype
- Stack
- ROS 2 · Nav2 · Python · OpenCV
- Impact
- Map-to-Nav2 coverage pipeline
What I did
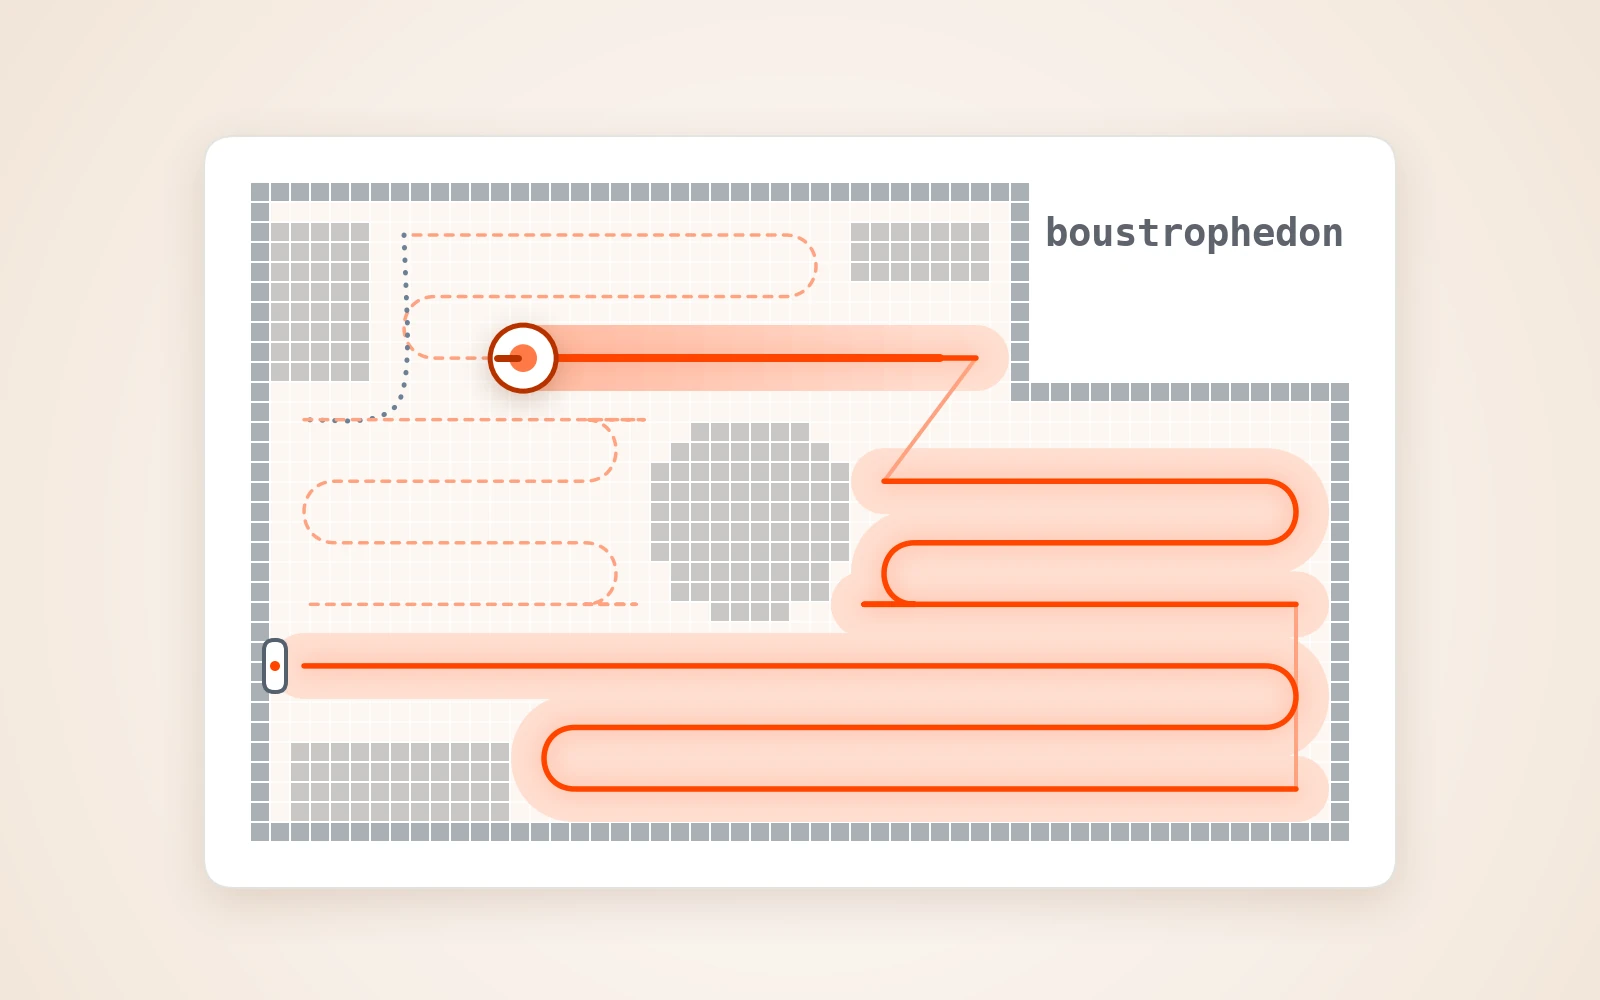
I wrote a coverage path planner for a ROS 2 floor-cleaning robot. It turns a SLAM occupancy map into parallel sweep passes, checks each pass against the robot's footprint so it does not hit walls, orders the passes, and sends them to Nav2 as a sequence of goals.
I also put the robot's software together: its URDF description, launch files, and the Cartographer and Nav2 setup. The sensor drivers and the SLAM and navigation packages themselves are standard open-source ROS packages.